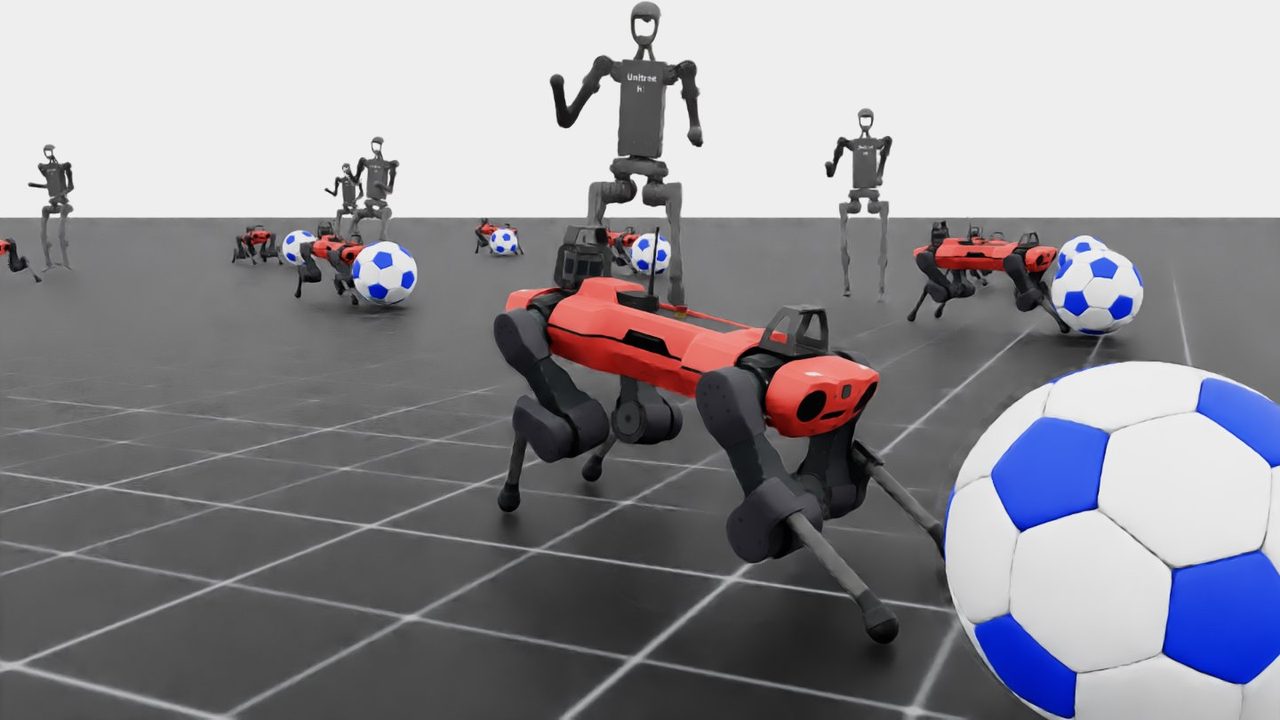
Heterogeneous multi-agent learning in Isaac Lab
Brought heterogeneous-agent RL algorithms into NVIDIA Isaac Lab so teams of different robots can learn to work together in GPU-parallel physics simulation.
I build learning systems for robots: heterogeneous multi-agent reinforcement learning at GPU scale, imitation learning, and 3D perception.
Co-founder & CTO at Strawberry Robotics. M.S. Computer Science, Utah State University. Open to research and engineering roles in AI, including AI safety.
Brought heterogeneous-agent RL algorithms into NVIDIA Isaac Lab so teams of different robots can learn to work together in GPU-parallel physics simulation.
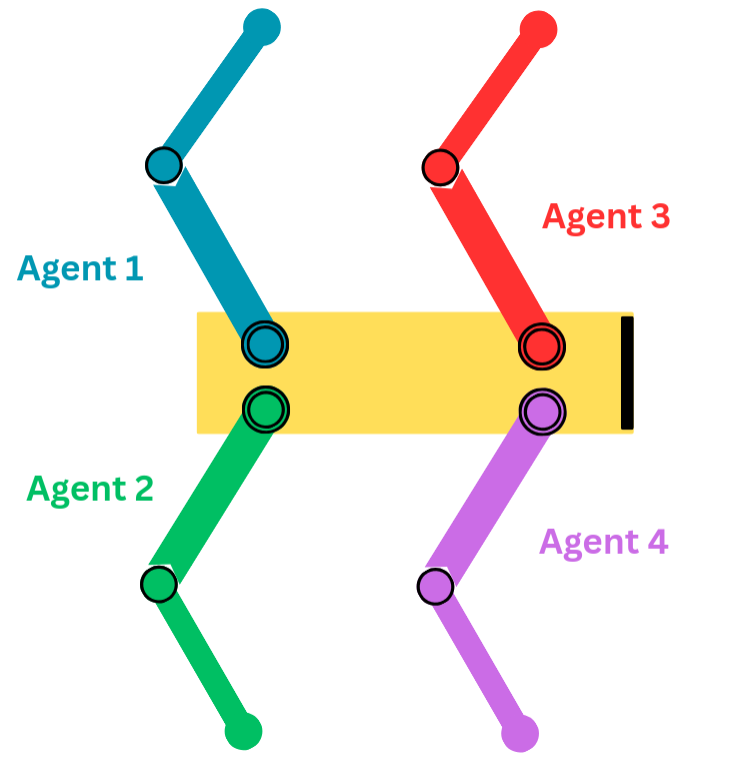
Split a Spot quadruped into cooperating agents, one per leg or joint group, and showed that HAPPO's sequential updates learn a better-coordinated gait at almost no cost in training speed.
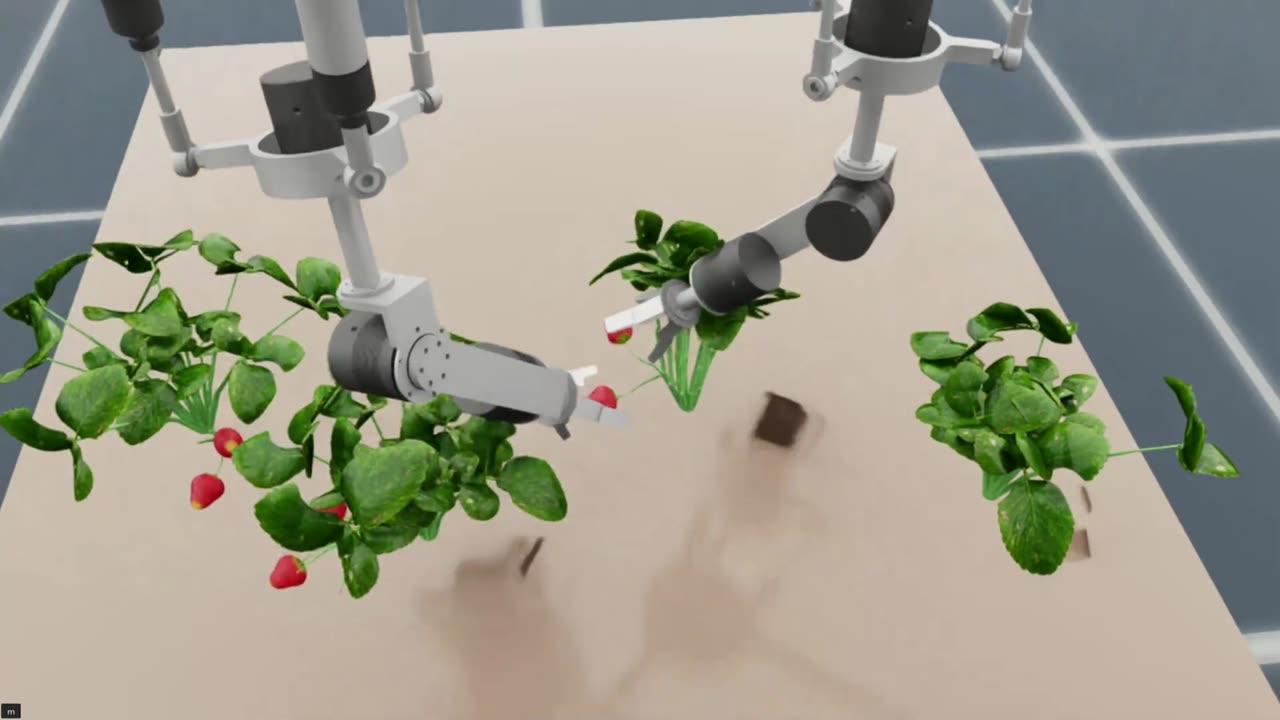
Led the AI side of a two-armed strawberry harvesting robot: Isaac Sim environments, a kinematics simulator, 3D berry and stem perception, and robot learning.
Implemented the Multi-Agent Transformer in Isaac Sim to coordinate a team of different robots searching unstructured outdoor environments.
Two-day prototype: a Chrome extension that highlights the next button to click toward a goal like "cancel my subscription." You make every click, and it warns before steps that can't be undone.
ROS 2 rover that maps its surroundings and points toward nearby people, with a YOLO model fine-tuned on infrared images running on a Jetson Nano.
Tested whether graph-structured scene information helps recurrent APPO agents in VizDoom.
Agents that learn the card game Hearts, with a custom Gym environment.
Internal applications in JavaScript, C#, and SQL.